Design and build
AUVs for RoboSub and related challenges, from hull form and thruster layout to pressure housings and mass budget.
 Get in touch
Team AUV · VIT Pune
A student team building autonomous underwater vehicles. Mechanical design, embedded systems, controls and perception, taken from CAD through simulation to the tank.
What we do
AUVs for RoboSub and related challenges, from hull form and thruster layout to pressure housings and mass budget.
Sensing, navigation and onboard autonomy running on embedded flight hardware, with real sonar in the loop.
Hardware and software proven in simulation and on the bench before anything goes into a tank.
Selected work
Autonomous underwater reconnaissance for post-flood disaster response. A vehicle designed for opaque, fast water where divers cannot work and optical cameras see nothing.
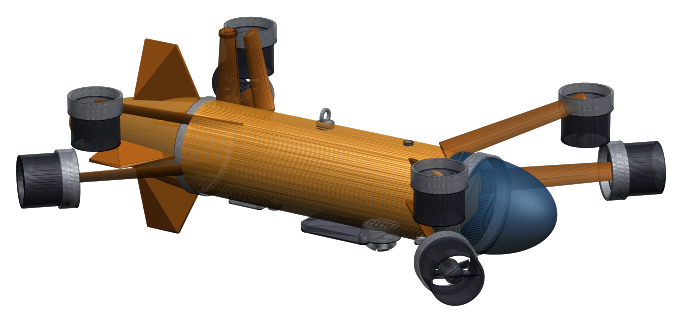
Loading model
Drag to rotate
Per subsystem, on the 9 point scale. The autonomy stack flies on real flight hardware. No physical vehicle exists yet and nothing has been in water.